Category: Mobile Robotics
-
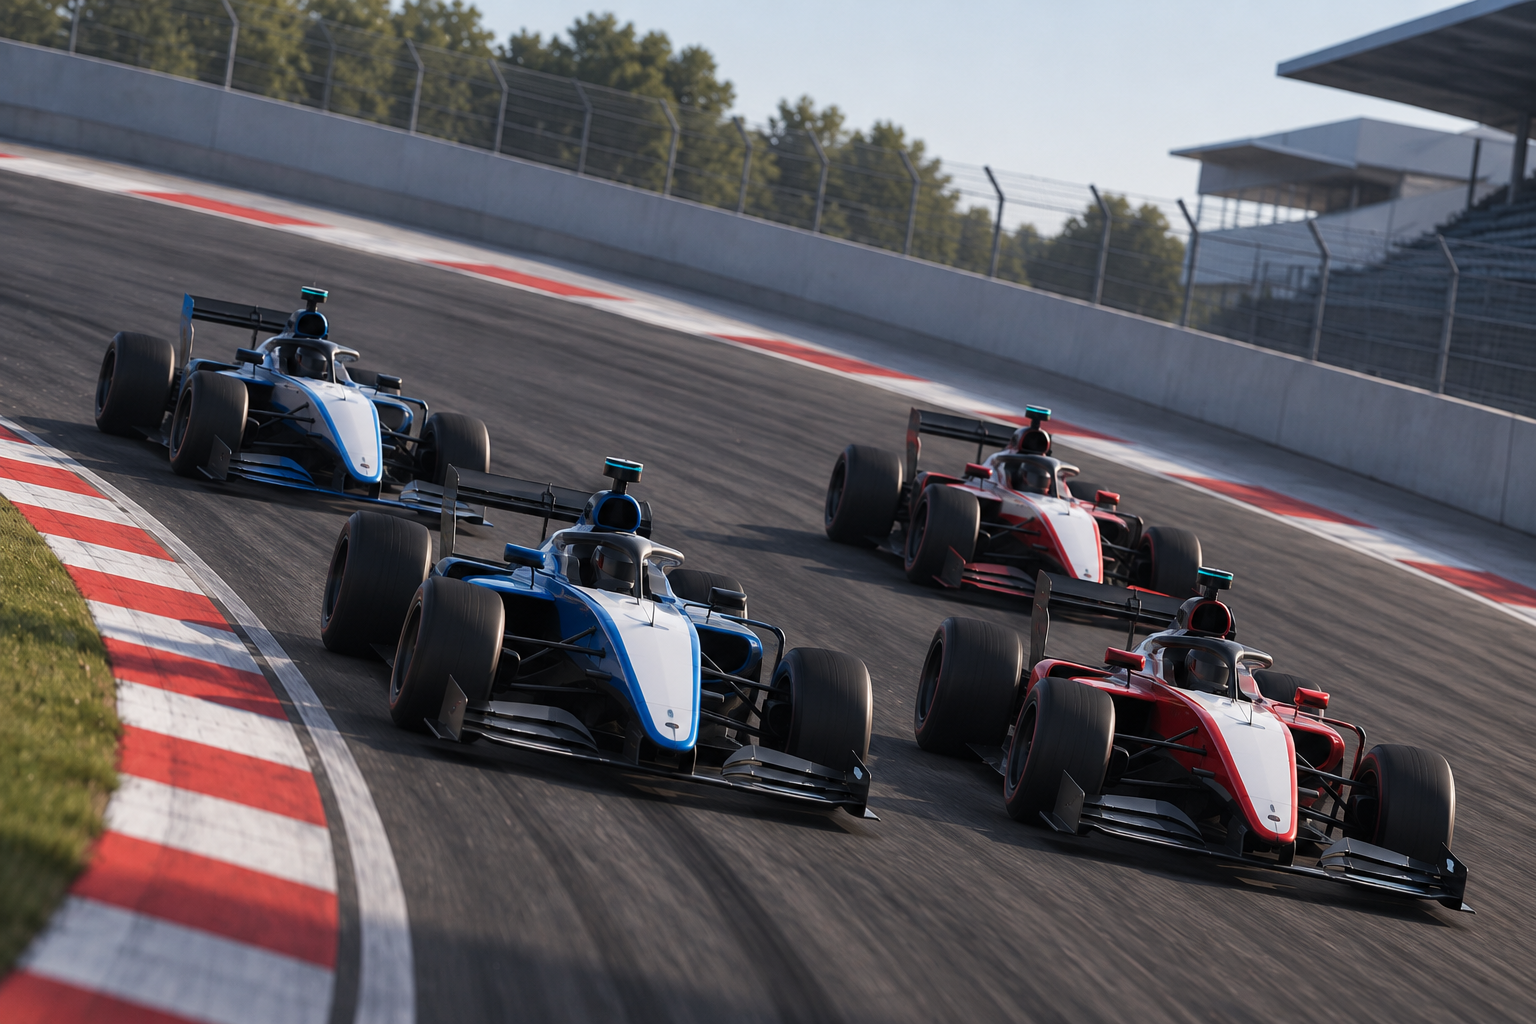
Cooperative-Competitive Autonomous Racing through Joint Latent Imagination
Introduction Multi-agent autonomous racing requires agents to balance individual performance, cooperation with teammates and competition against opponents. In a 2-vs-2 setting, effective decisions may involve coordinated overtaking, defensive blocking or sacrificing short-term individual performance to improve the team outcome. Model-based reinforcement learning provides a promising framework for this problem by learning a predictive world model…
-
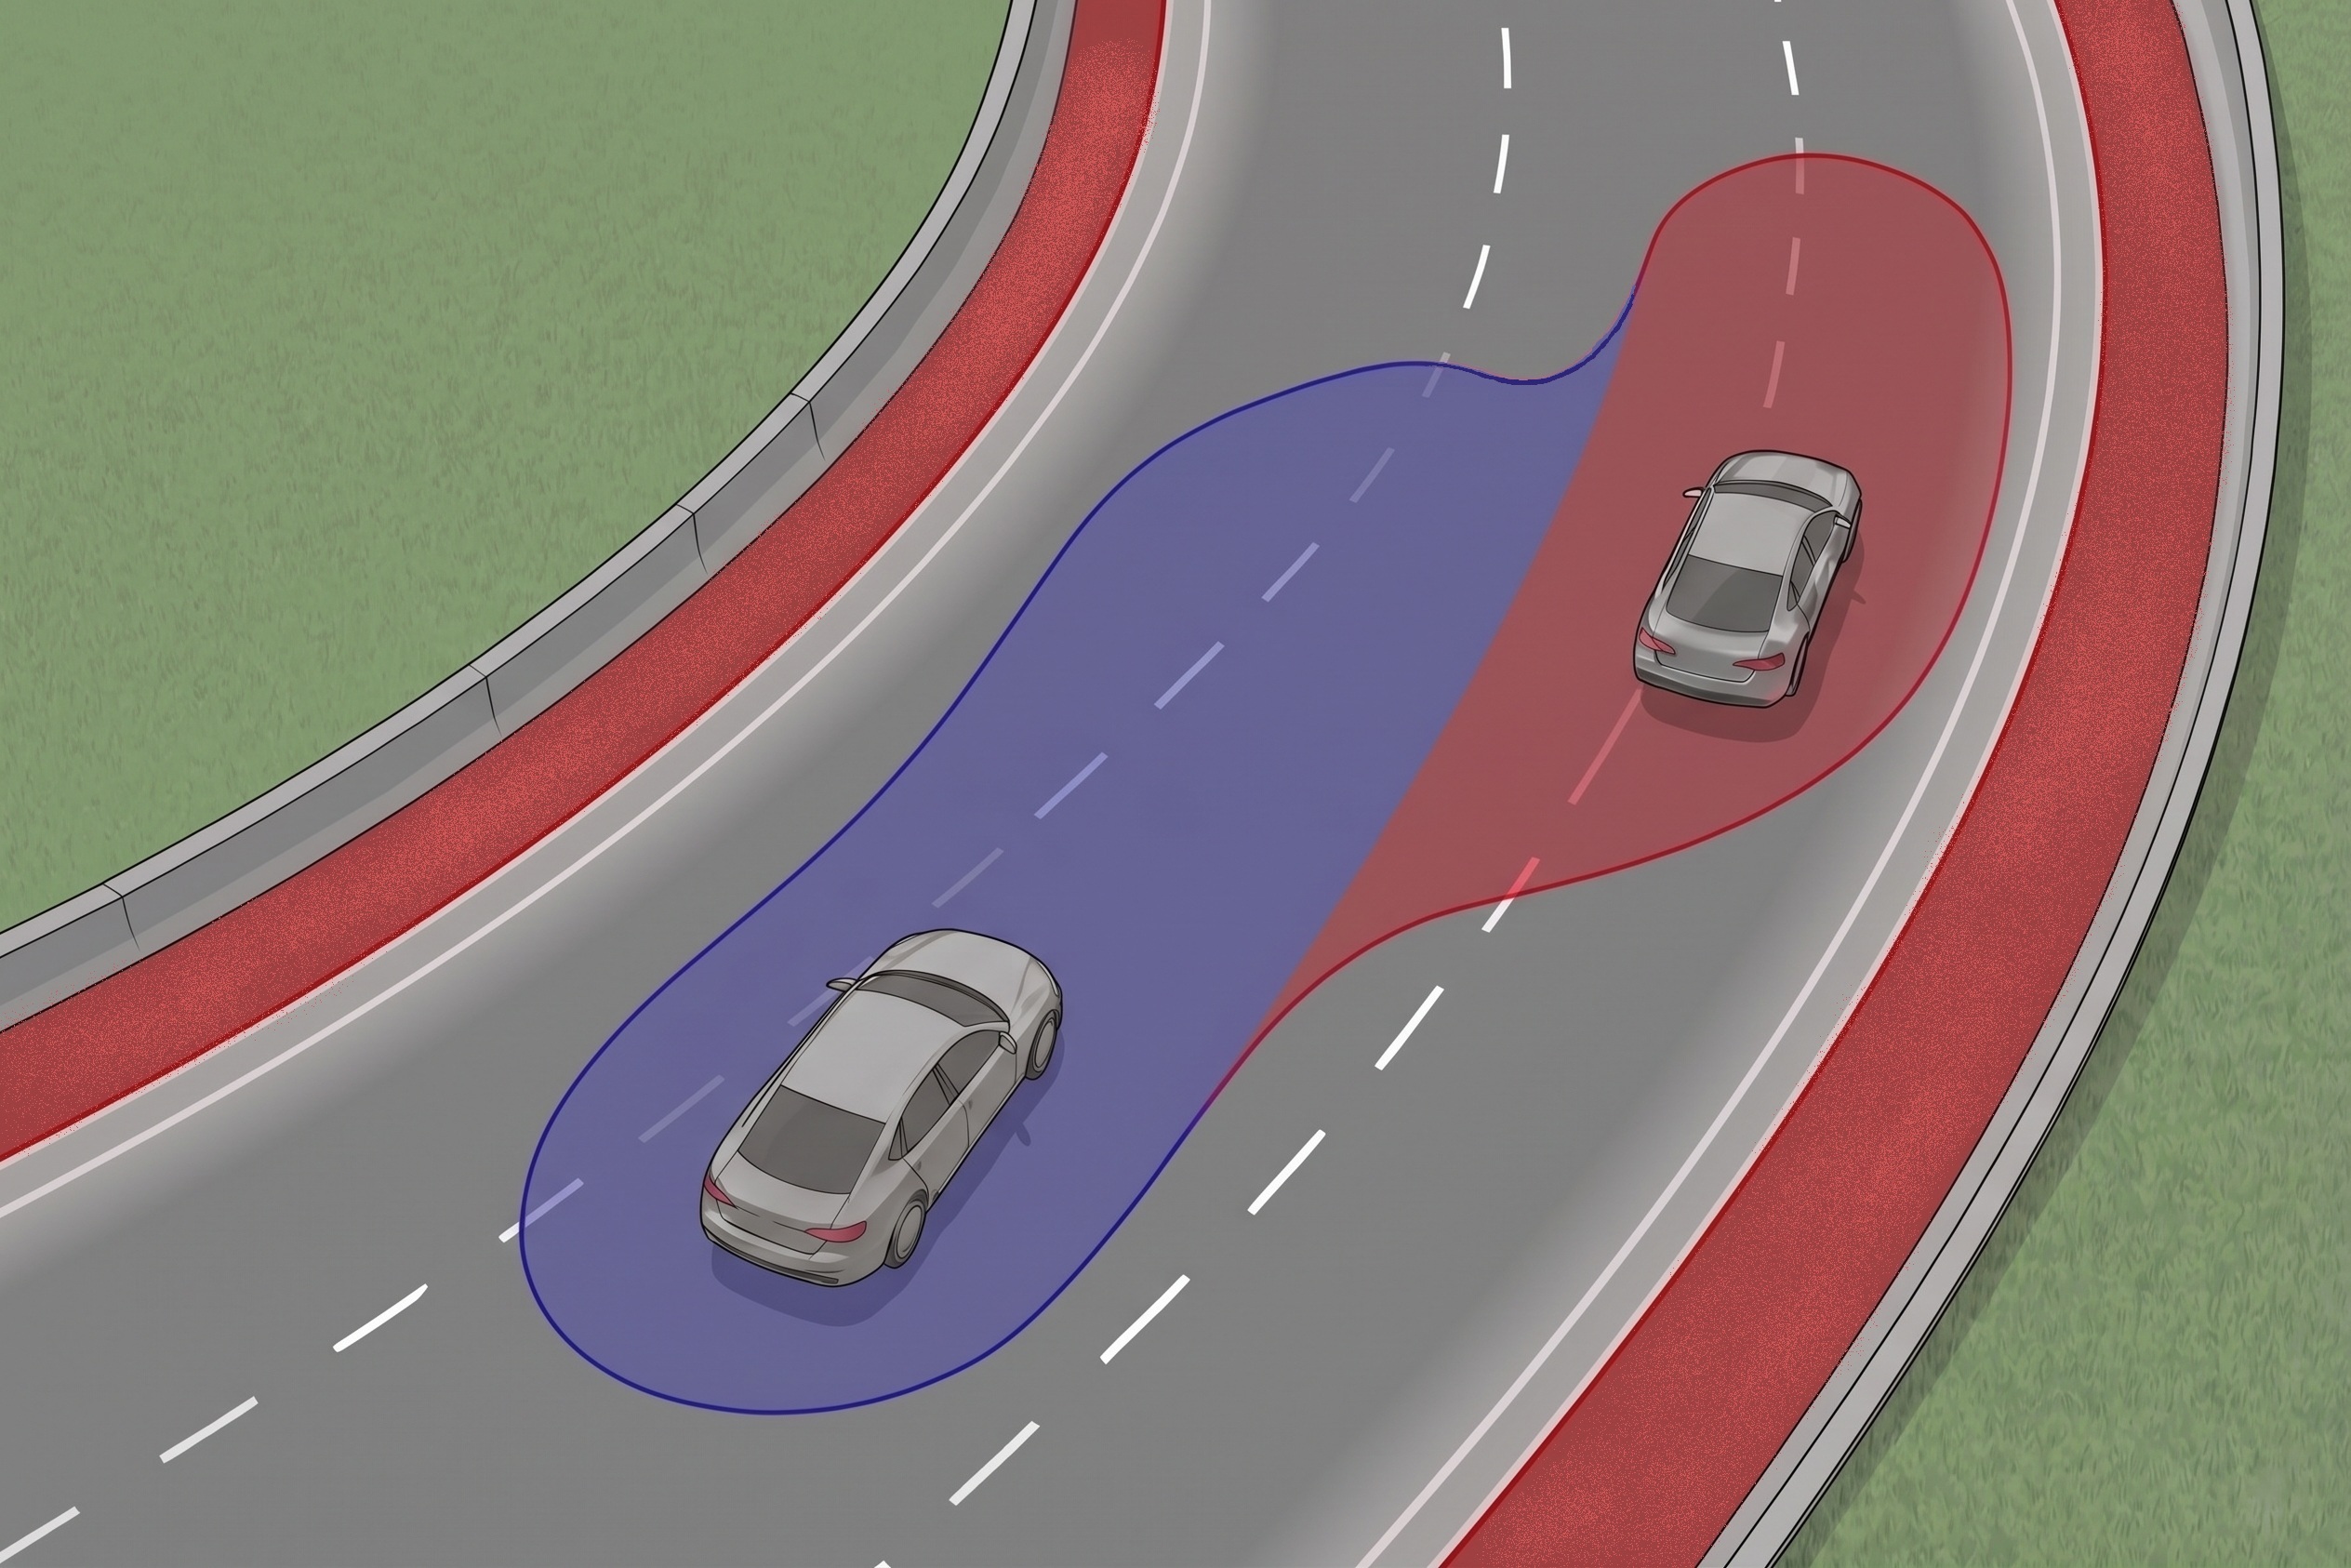
Environment-Aware Collision Avoidance for Multi-Agent Navigation
Introduction Safe autonomous navigation requires reasoning not only about how other agents may move, but also about which maneuvers are compatible with the surrounding environment. Hamilton–Jacobi (HJ) reachability can provide a framework for collision avoidance under worst-case interactions. Environmental constraints can already be included in HJ formulations, but combining geometry and multi-agent interaction can significantly…
-

Reduced-order aeroelastic modeling and control of inflatable multirotor drones
Inflatable and soft structures offer interesting opportunities for the development of lightweight, compact, and deployable aerial vehicles. In particular, multirotor drones based on inflatable structural frames could combine conventional propulsion and control systems with lightweight and compliant supporting structures. Such configurations may enable drones that can be compactly stored and rapidly deployed, while also providing…
-
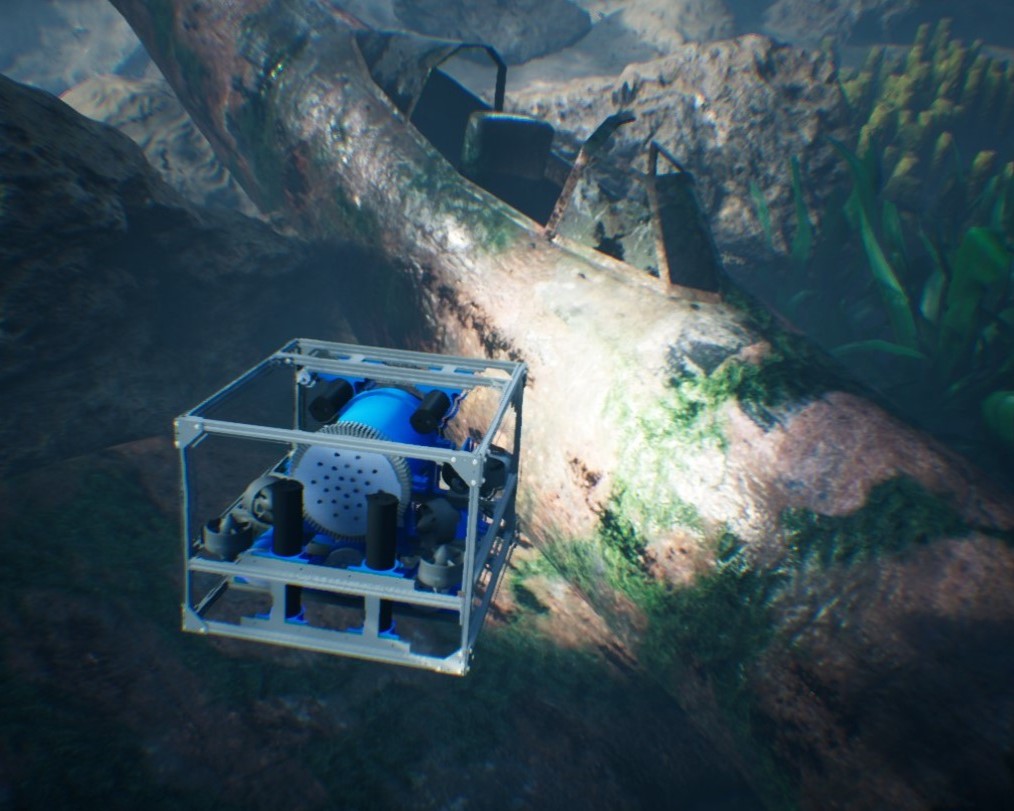
Bridging Simulation and Reality for Autonomous Underwater Vehicles
Autonomous Underwater Vehicles (AUV) are subject to highly non-linear hydrodynamic forces, significant parametric uncertainty, and unpredictable environmental disturbances, all of which make robust low-level control a persistent open challenge. This thesis investigates control strategies for AUV motion control with a focus on robustness, the ability of a controller to maintain acceptable performance despite uncertainty in…
-
Fall Recovery for Quadrupeds
Introduction Legged robots operating in real-world environments are inevitably exposed to disturbances, uneven terrain, and interaction forces that can lead to loss of balance and falls. Robust fall recovery is therefore a critical capability for enabling truly autonomous deployment of quadruped robots in unstructured settings. While traditional approaches rely on hand-crafted reflexes or carefully engineered…
-

Fall Recovery for Humanoid Robots
Introduction Humanoid robots are designed to operate in human-centered environments, where unexpected contacts, uneven terrain, and external disturbances frequently lead to loss of balance and falls. Reliable fall recovery is therefore a key capability for long-term autonomous operation and human–robot coexistence. Classical approaches rely on carefully engineered whole-body controllers and pre-defined get-up sequences, which are…
-
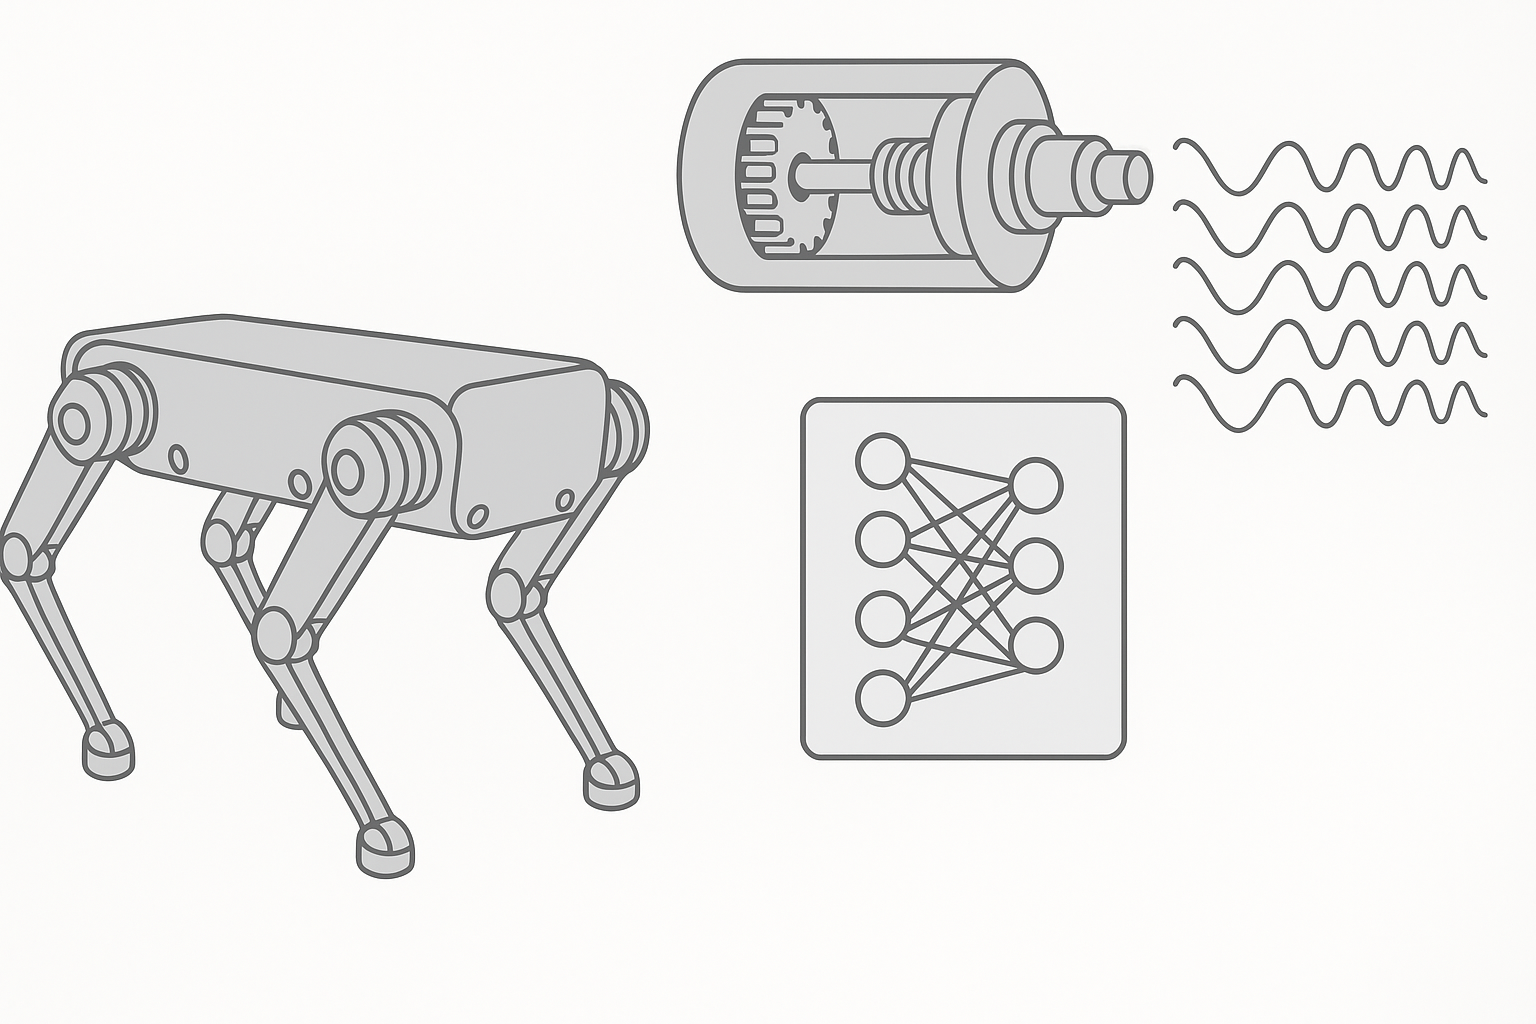
Actuator Modeling
Introduction Recent advances in GPU-based physics simulation and deep Reinforcement Learning (RL) have enabled the rapid training of control policies for complex, highly articulated robots such as quadrupeds and humanoids. Parallelized simulators now make it possible to obtain policies that transfer to hardware in a matter of minutes of simulated experience [1]. Despite this progress,…
-
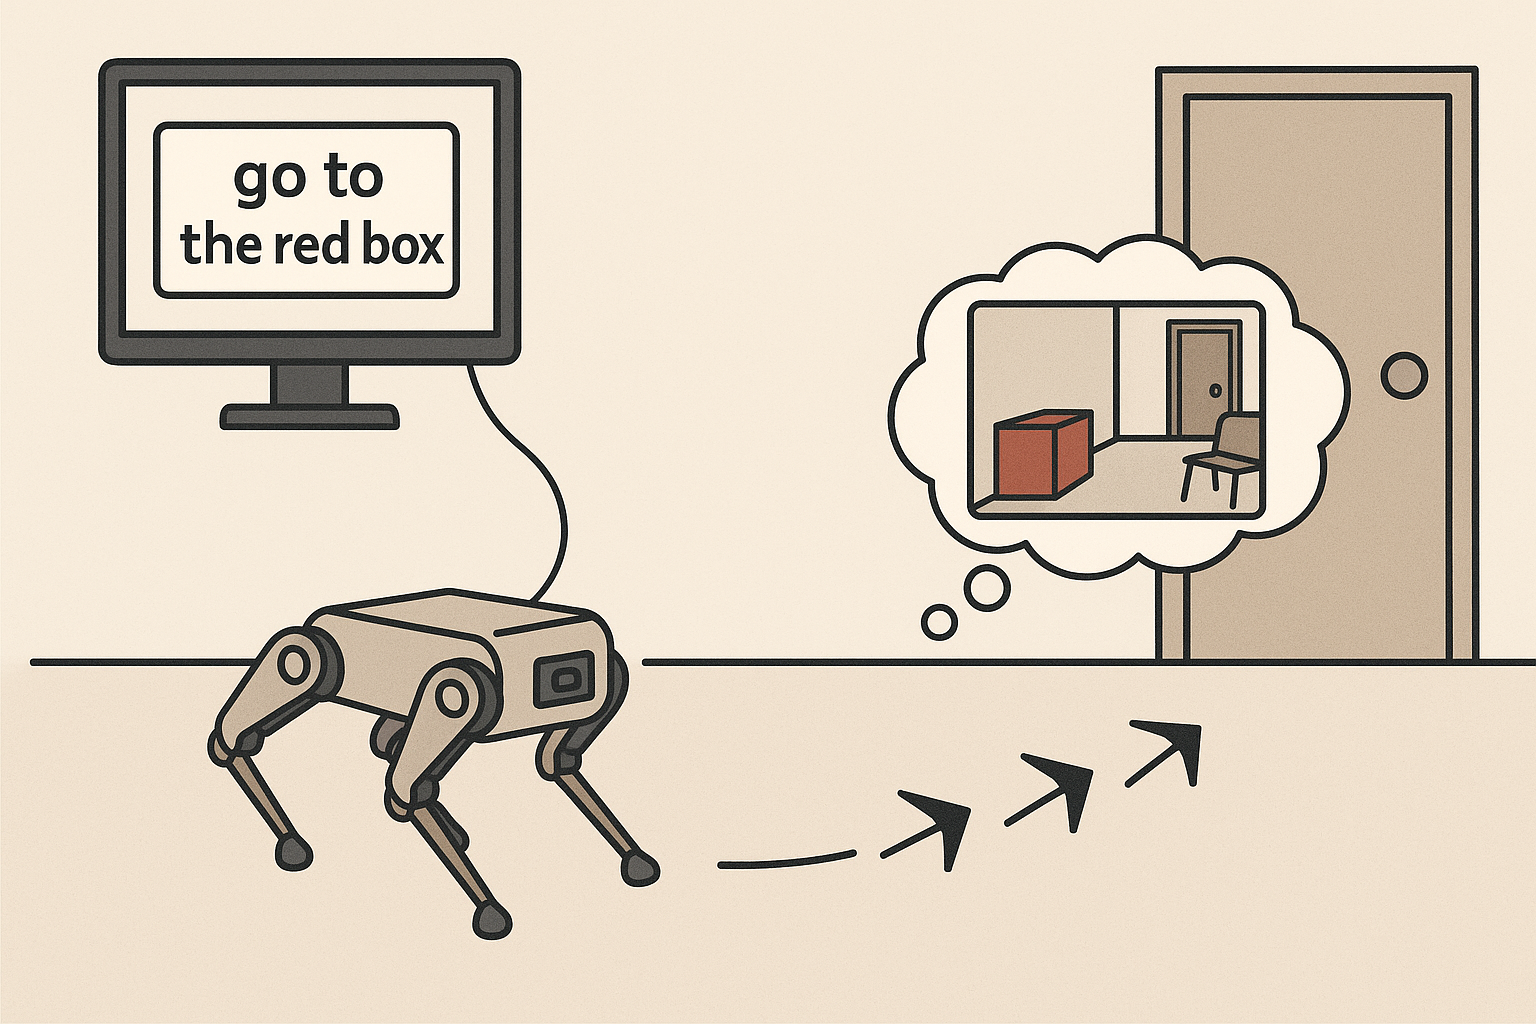
VLAs for Navigation
Introduction Vision-Language-Action (VLA) models have recently emerged as a powerful paradigm for grounding natural-language instructions in perception and control, enabling robots to execute high-level commands specified in human-friendly terms. In this project, we consider a navigation setting in which a mobile robot (Unitree GO2) receives an egocentric RGB-D observation together with a short natural-language instruction…
-

Quadruped Teleoperation System
Introduction Reinforcement Learning (RL) has recently enabled agile and dynamic behaviors in legged robots. However, RL alone is not always the most suitable tool, especially for sparse, long-horizon tasks that involve complex object manipulation. Even with careful problem formulation, reward design, and curriculum learning, such tasks can remain difficult to solve using standard RL methods.…