Category: Robotics
-
Study of the propulsive performance of fins
The most common propulsive strategy of fishes and cetaceans is the Body-Caudal fin movement in which the animal undulates or oscillates its body, pushing backward the surrounding water. Most of the thrust is generated by the movement of the caudal fin, and every fish has a peculiar fin shape with a particular motion law, which…
-
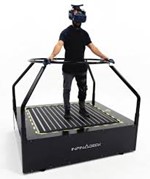
Development of a training simulator for industrial applications
Immersive simulation systems can be used as training systems but also as systems for monitoring user behaviour. Through behaviour mapping, it is possible to develop safety logic and algorithms with which production systems can be improved. In this thesis, a multidirectional treadmill is used to recreate a demo of a work situation suitable for both…